 Nanjing University · School of Intelligent Science and Technology
SOARLAB
Flying General Intelligence Lab
Flying robots, embodied agents, real systems. Led by Hao Xu, we build embodied and collaborative intelligence for aerial robots, humanoids, and emerging flying humanoid platforms, with a focus on robotics agents, world/action models, VLA-style robot foundation models, distributed perception, SLAM, and reinforcement learning.
Highlights
Recent Work
Join us
2027 Admissions
We are recruiting direct Ph.D., regular Ph.D., and master's students from the 2027 cohort who are interested in embodied intelligence, robotics, and core algorithms. The most urgent directions are WAM/VLA and AI agents, while strong students in distributed perception, SLAM, and reinforcement learning are also welcome.
PI
Principal Investigator
 Nanjing UniversitySchool of Intelligent Science and Technology
Hao Xu received his Ph.D. from the Department of Electronic and Computer Engineering at the Hong Kong University of Science and Technology, supervised by Prof. Shaojie Shen. He has worked as a multi-sensor information fusion algorithm engineer at DJI and as an associate researcher at Beihang University, and joins Nanjing University as a tenure-track associate professor. His prior work spans spatial intelligence for aerial and legged robots, aerial swarm state estimation, distributed SLAM, and autonomous swarm systems; his future research centers on embodied and collaborative intelligence.
Dr. Xu has published in major robotics journals and conferences including IEEE TRO, IEEE RAL, ICRA, and IROS, and serves as a reviewer for these venues. The collaborative work RACER received the IEEE Transactions on Robotics King-Sun Fu Memorial Best Paper Award, the first time this award went to a team from China. His released systems include D2SLAM, Omni-Swarm, VINS-Fisheye, and FoxTracker.
Research
Research Pillars
Robotics Agent
Agent-oriented perception, planning/control, world models, simulation, and behavior decision-making for robots operating under real hardware constraints.
WAM/VLA Robot Foundation Models
World-action and vision-language-action modeling for robot foundation models validated on aerial robots, humanoids, and flying humanoid platforms.
Distributed Perception & Swarms
Distributed SLAM, aerial swarm state estimation, reinforcement learning, and autonomous swarm systems, building on the lab's long-standing core robotics work.
Latest
News
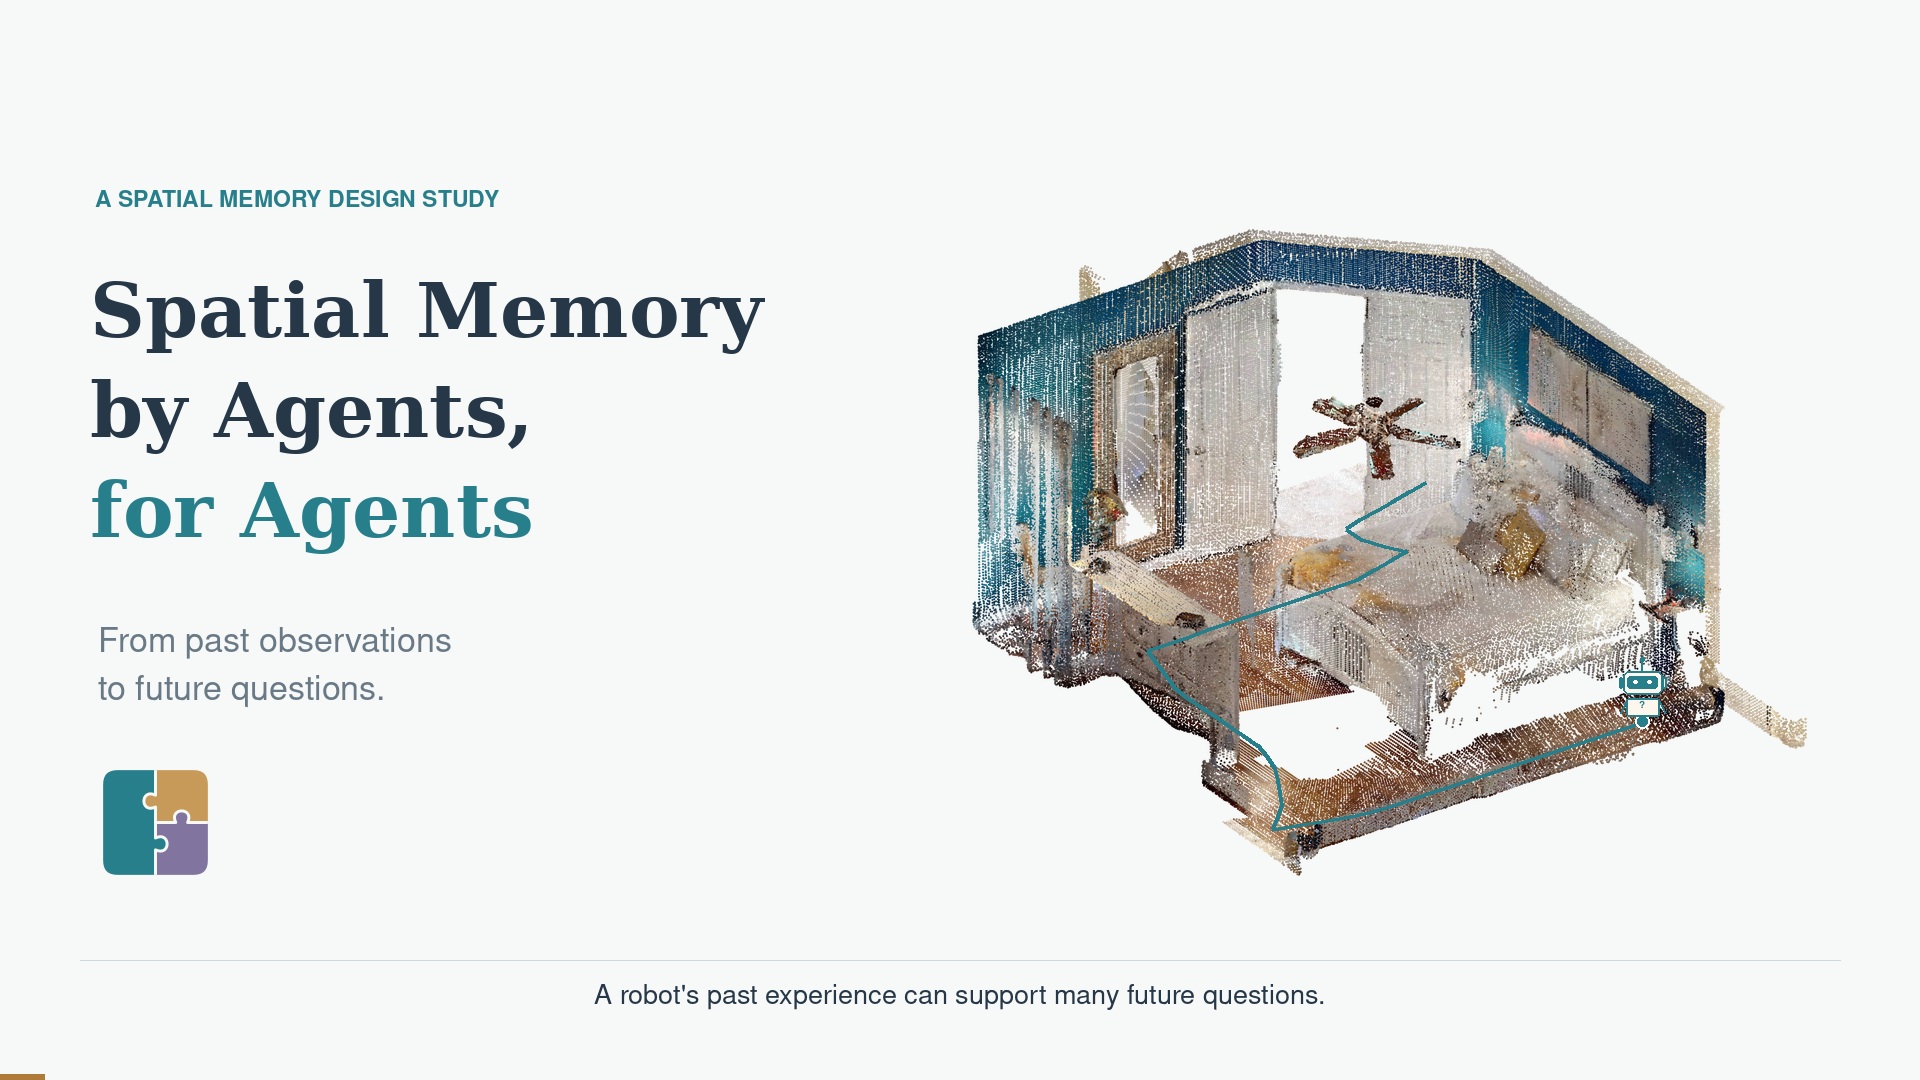
All news →- New preprint: Spatial Memory by Agents, for Agents. Coding agents design a robot’s spatial memory by writing code, running benchmarks, and iterating on feedback. We call this Guided System Improvement (GSI). Across five task tracks, the best configuration improves the average unified score by about 51% over the strongest all-task baseline. Joint work with Mondo Robotics. arXiv · Project page
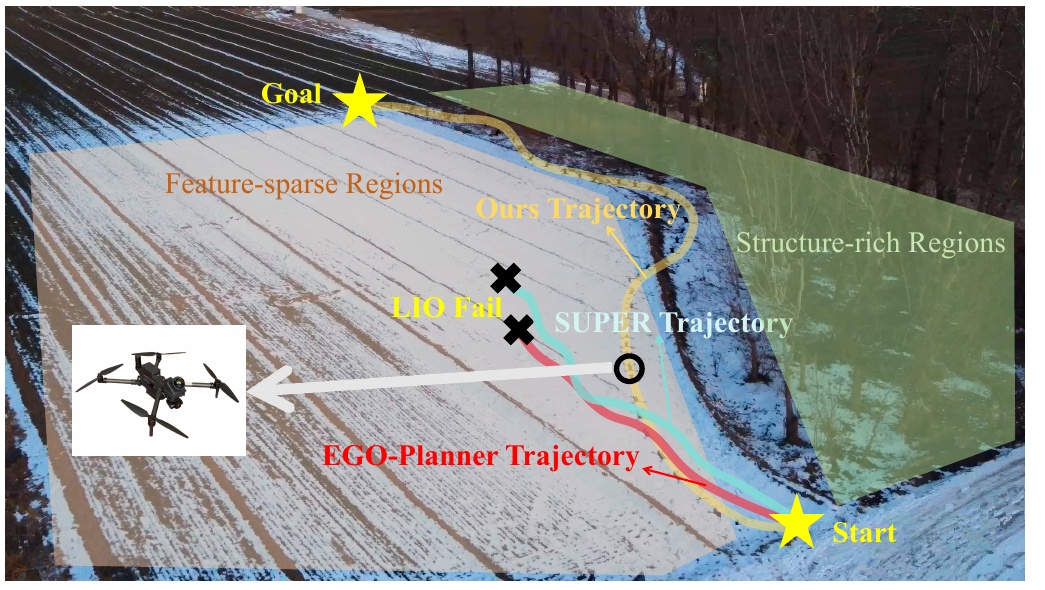
- Our collaborative paper AUG: Perception-Aware UAV Graph-Based Planning for GNSS-Denied Navigation in Feature-Sparse Environments received an Honorable Mention for the IROS 2026 Best Paper Award on Safety, Security, and Rescue Robotics.
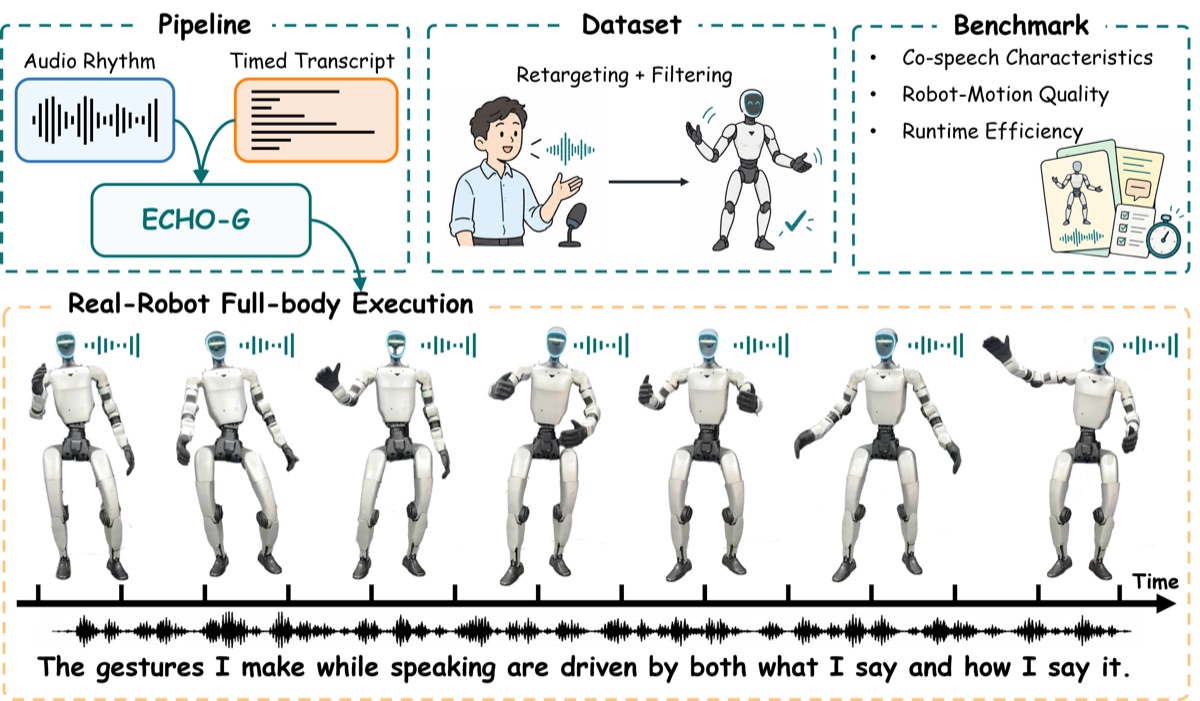
- ECHO-G is out: humanoid robots that gesture while they talk, landing each move on the beat. ECHO-G combines text and speech latents for semantically rich full-body gestures with end-to-end whole-body control, and runs on an embedded Jetson Orin AGX. Joint work with Mondo Robotics and the HKUST Aerial Robotics Group. arXiv · Code · Video
- Early members will help build the lab’s infrastructure, including compute servers, experimental space, and UAV and robot validation platforms.
- Our most urgent directions are WAM/VLA robot foundation models and AI agents. Students with strong interests in distributed perception, SLAM, reinforcement learning, aerial swarms, and real robotic systems are also welcome. See the recruiting page.
Research
Selected Publications
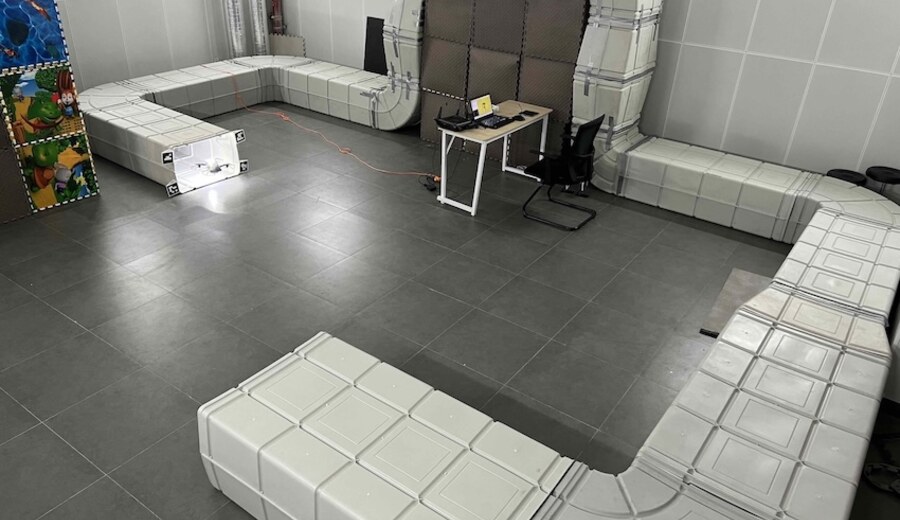
All publications →- Autonomous Flights Inside Narrow TunnelsIEEE Transactions on Robotics, 2025
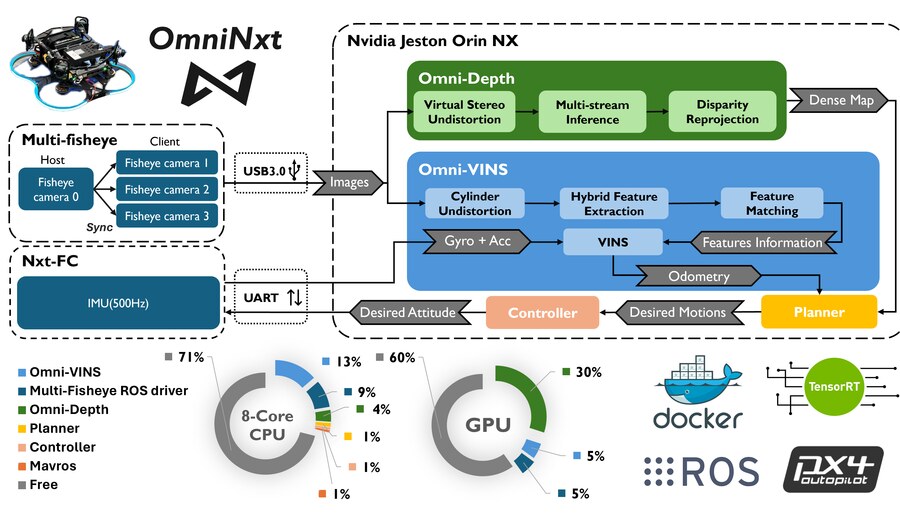
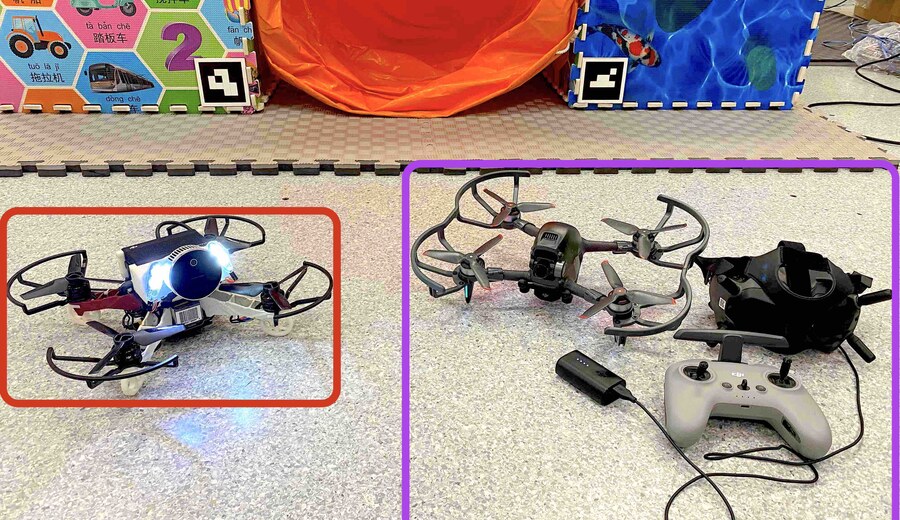
- OmniNxt: A Fully Open-Source and Compact Aerial Robot with Omnidirectional Visual PerceptionIn IEEE/RSJ International Conference on Intelligent Robots and Systems, 2024
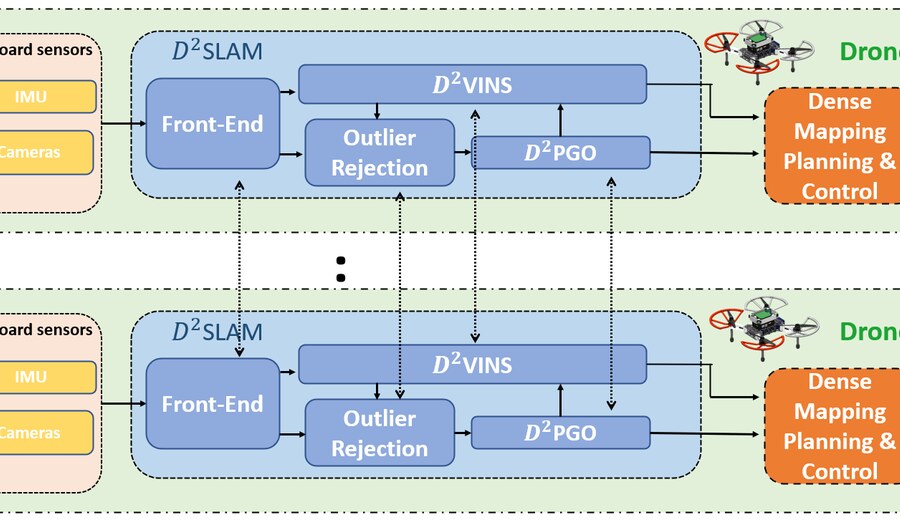
- D2SLAM: Decentralized and Distributed Collaborative Visual-Inertial SLAM System for Aerial SwarmIEEE Transactions on Robotics, 2024
- RACER: Rapid Collaborative Exploration With a Decentralized Multi-UAV SystemIEEE Transactions on Robotics, 2023
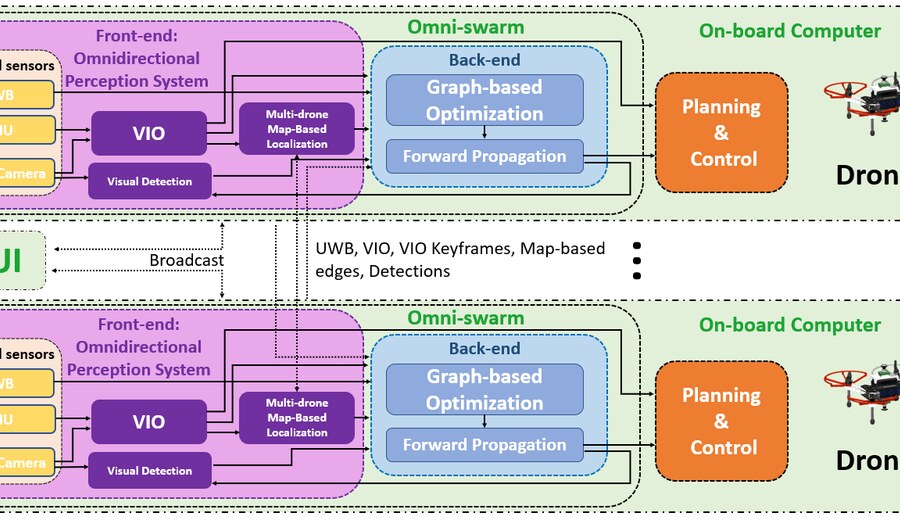
- Omni-Swarm: A Decentralized Omnidirectional Visual-Inertial-UWB State Estimation System for Aerial SwarmsIEEE Transactions on Robotics, 2022
- AUG: Perception-Aware UAV Graph-Based Planning for GNSS-Denied Navigation in Feature-Sparse EnvironmentsIn IEEE/RSJ International Conference on Intelligent Robots and Systems, 2026
- Neither Fast nor Slow: How to Fly Through Narrow TunnelsIEEE Robotics and Automation Letters, 2022
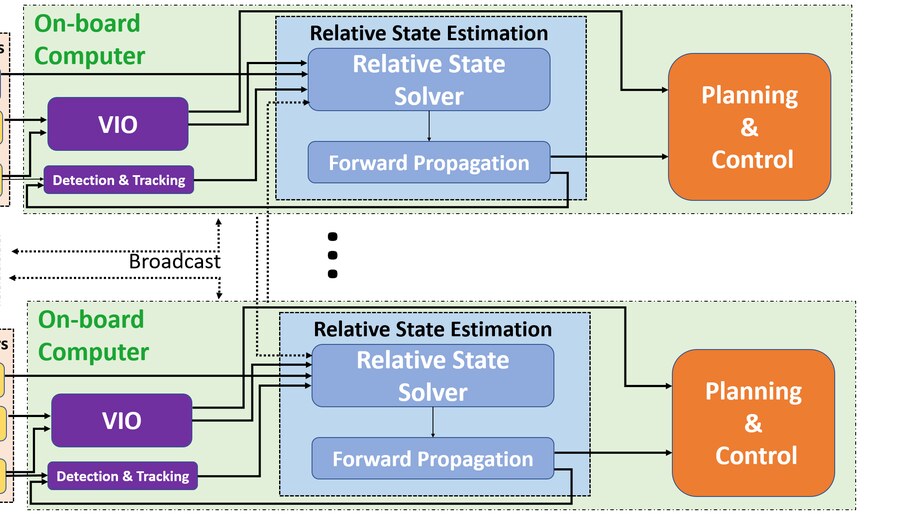
- Decentralized Visual-Inertial-UWB Fusion for Relative State Estimation of Aerial SwarmIn IEEE International Conference on Robotics and Automation, 2020